Projects
Real projects. Real constraints. Real solutions.
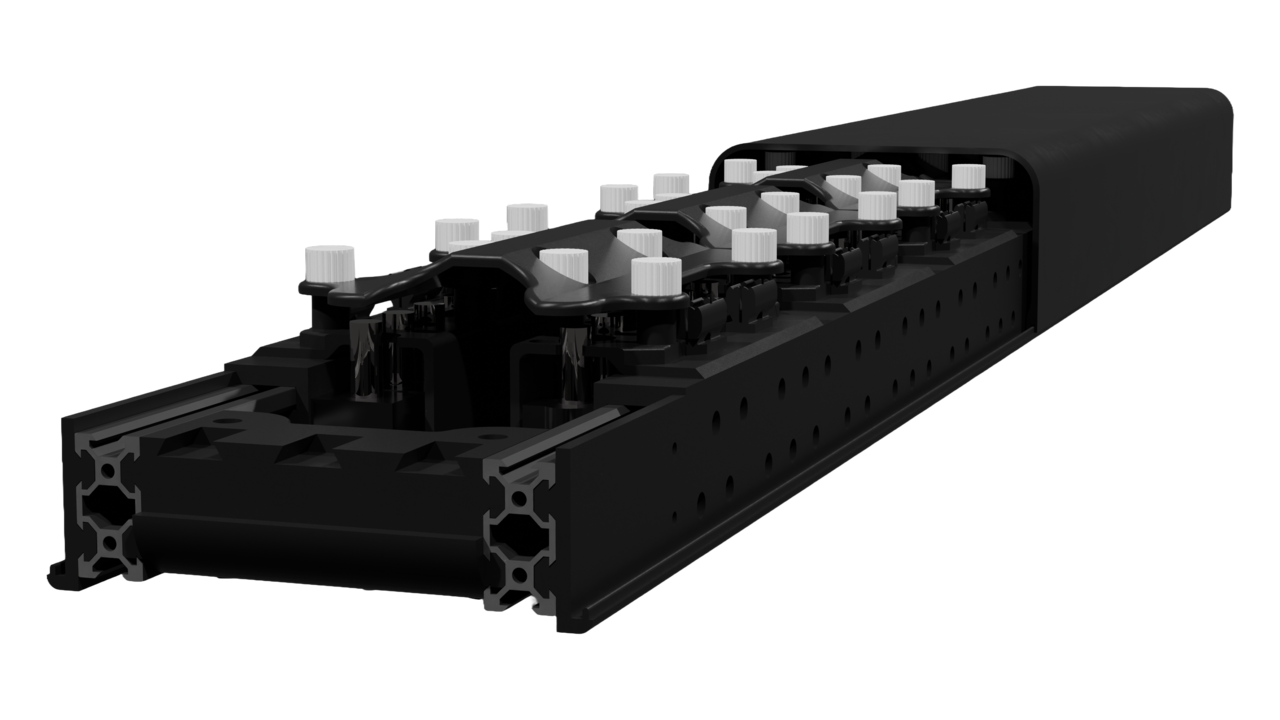
Autonomous Piano-Playing Robot
Lead Mechanical Engineer · Manufacturing · Data Analyst
Engineered an 88-key autonomous, modular piano-playing robot with human-like key actuations. Designed a lightweight FDM-printed structural frame optimized for high stiffness-to-weight ratio and modular assembly. Achieved 100% accuracy with intelligent design and consistent automation.
88-KEY · 100% ACCURACY · 90% COST REDUCTION · CUSTOM PCB
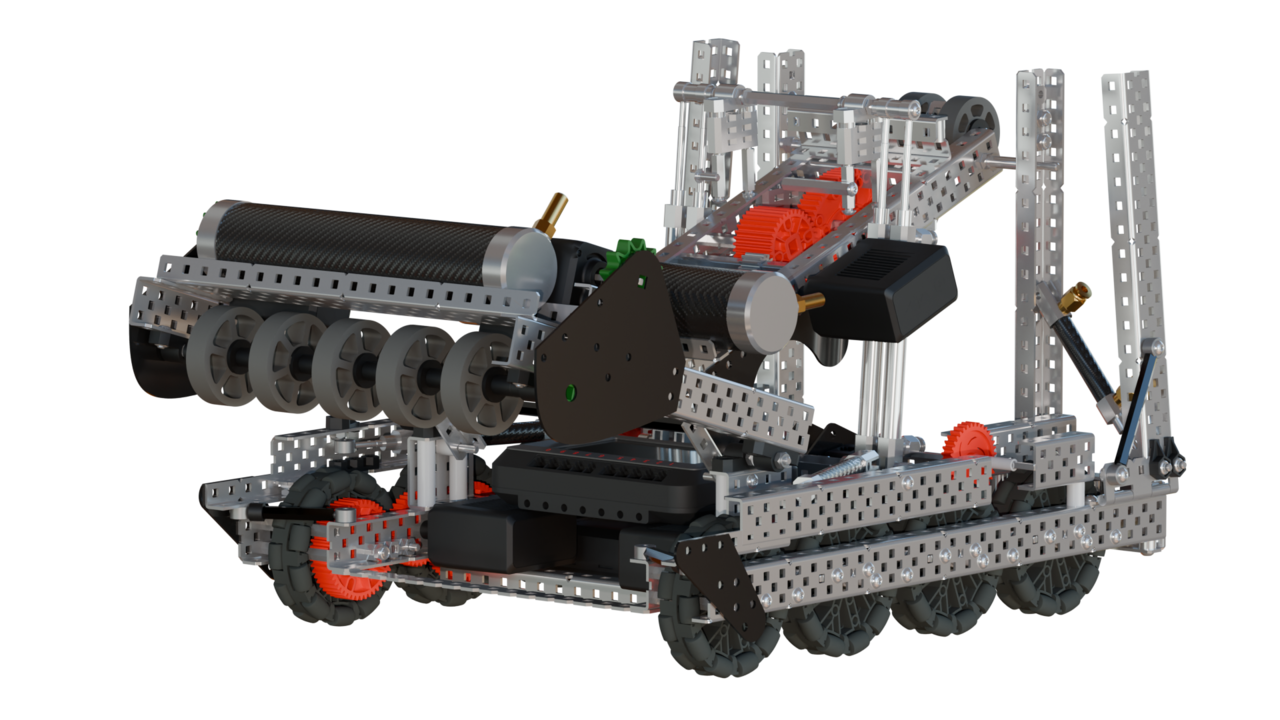
Competitive Robotics
Team Captain · Lead Mechanical Engineer · Driver · Programmer
Designed, built, tested, programmed, and drove 10+ competitive robots at the international level. Managed a 4-6 member competing team and was the captain to a 60+ member school program with 12 teams and a $10,000 annual budget. Ranked 7th globally in TrueSkill out of 10,000+ teams worldwide, 1st in BC out of 150+ teams.
7TH GLOBAL · 10,000+ TEAMS · 1ST IN BC
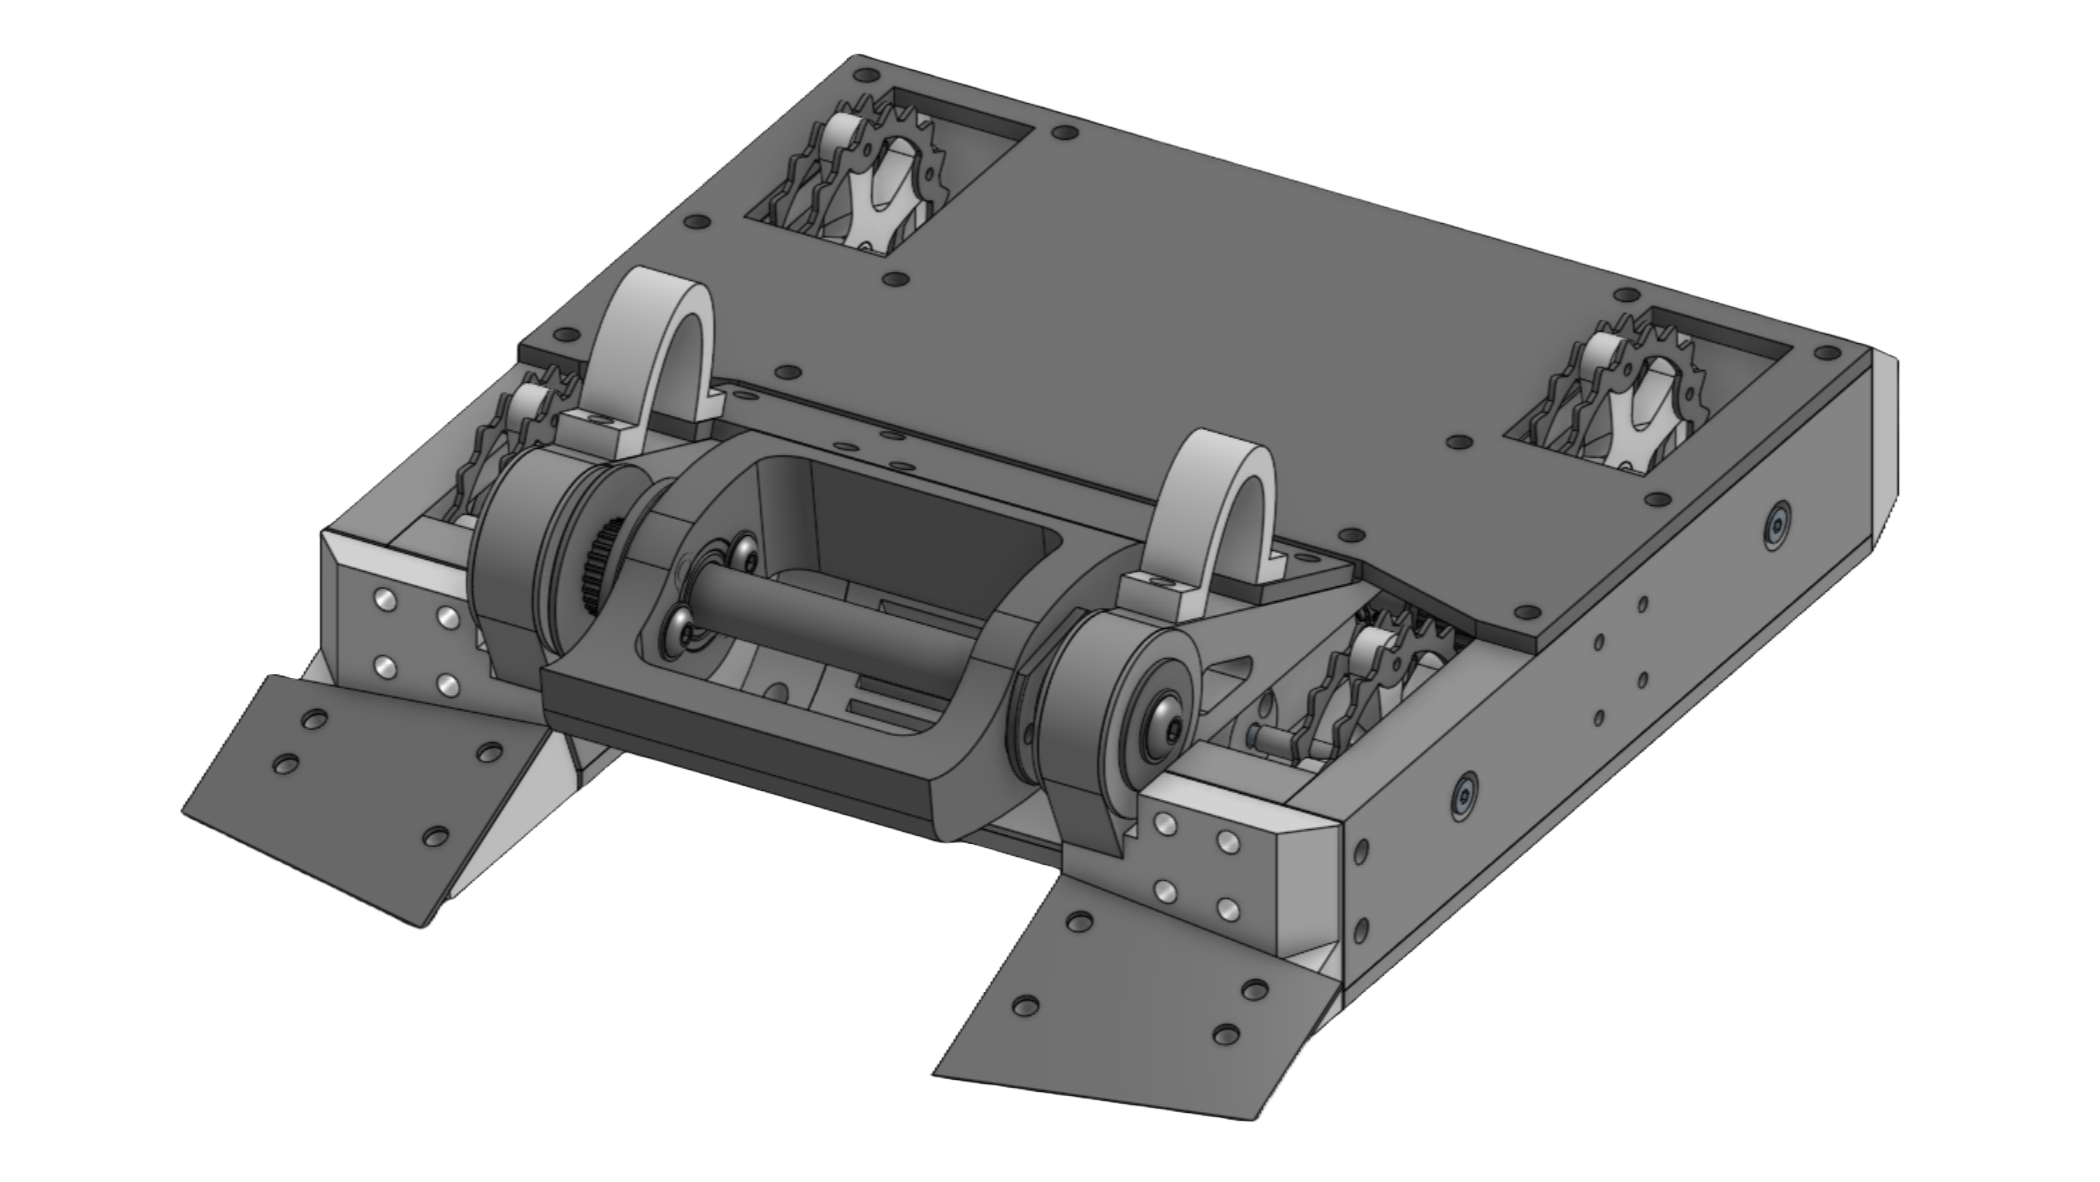
Waterloo Combat Robotics
Lead Mechanical Engineer
Designed a manufacturable, robust 3 lb beetleweight combat robot in SolidWorks from UHMW plastic, carbon fibre, hardened steel, and FDM-printed parts. Integrated structural reinforcement with electrical components for maximum repairability.
3LB BEETLEWEIGHT · ELECTROMECHANICAL SYSTEMS · RELIABLE AND CONSISTENT
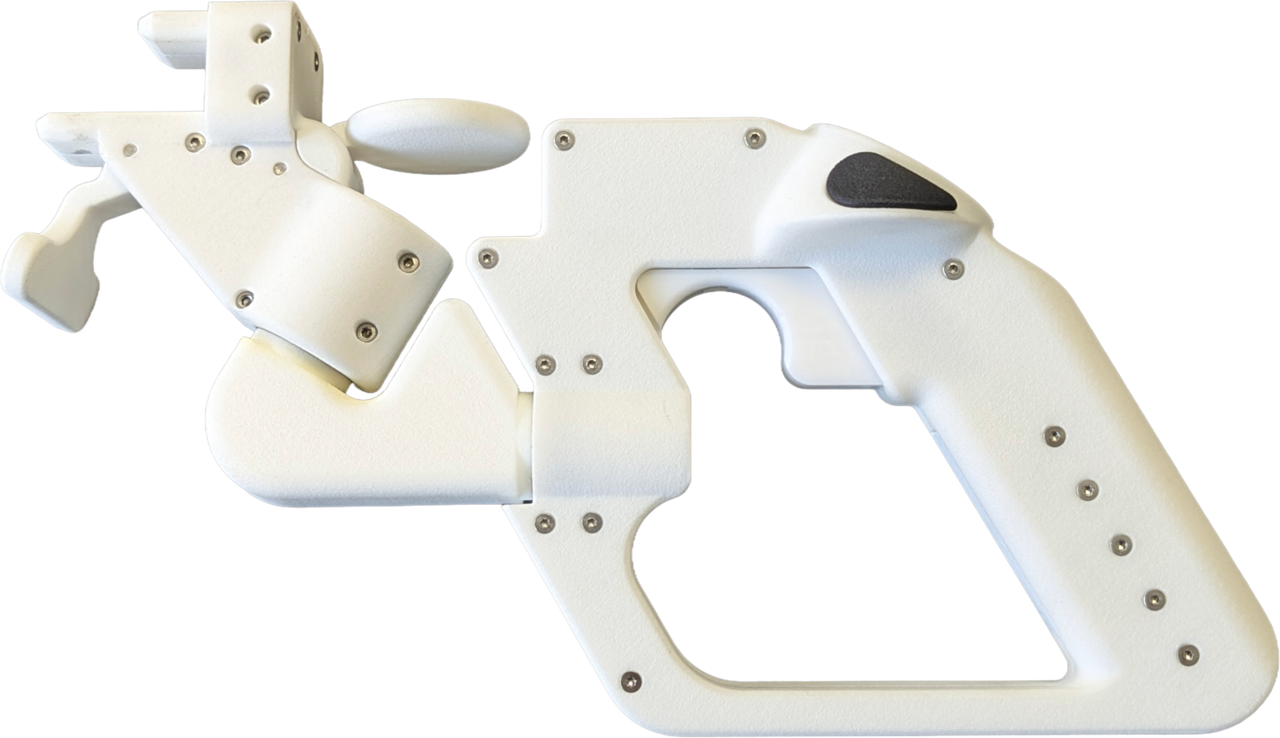
Surgical Robot Interface
Surgical Robot Designer · Revolve Surgical (YC)
Designed an intuitive ergonomic surgeon interface for 6+1 DOF wristed laparoscopic instruments. Developed a novel pivoting mechanism to reduce surgeon fatigue, iterated through surgeon feedback.
6+1 DOF ROBOT · CAN TELEMETRY · YC-BACKED
Personal Engineering Infrastructure
Full-Stack Developer · Systems Engineer
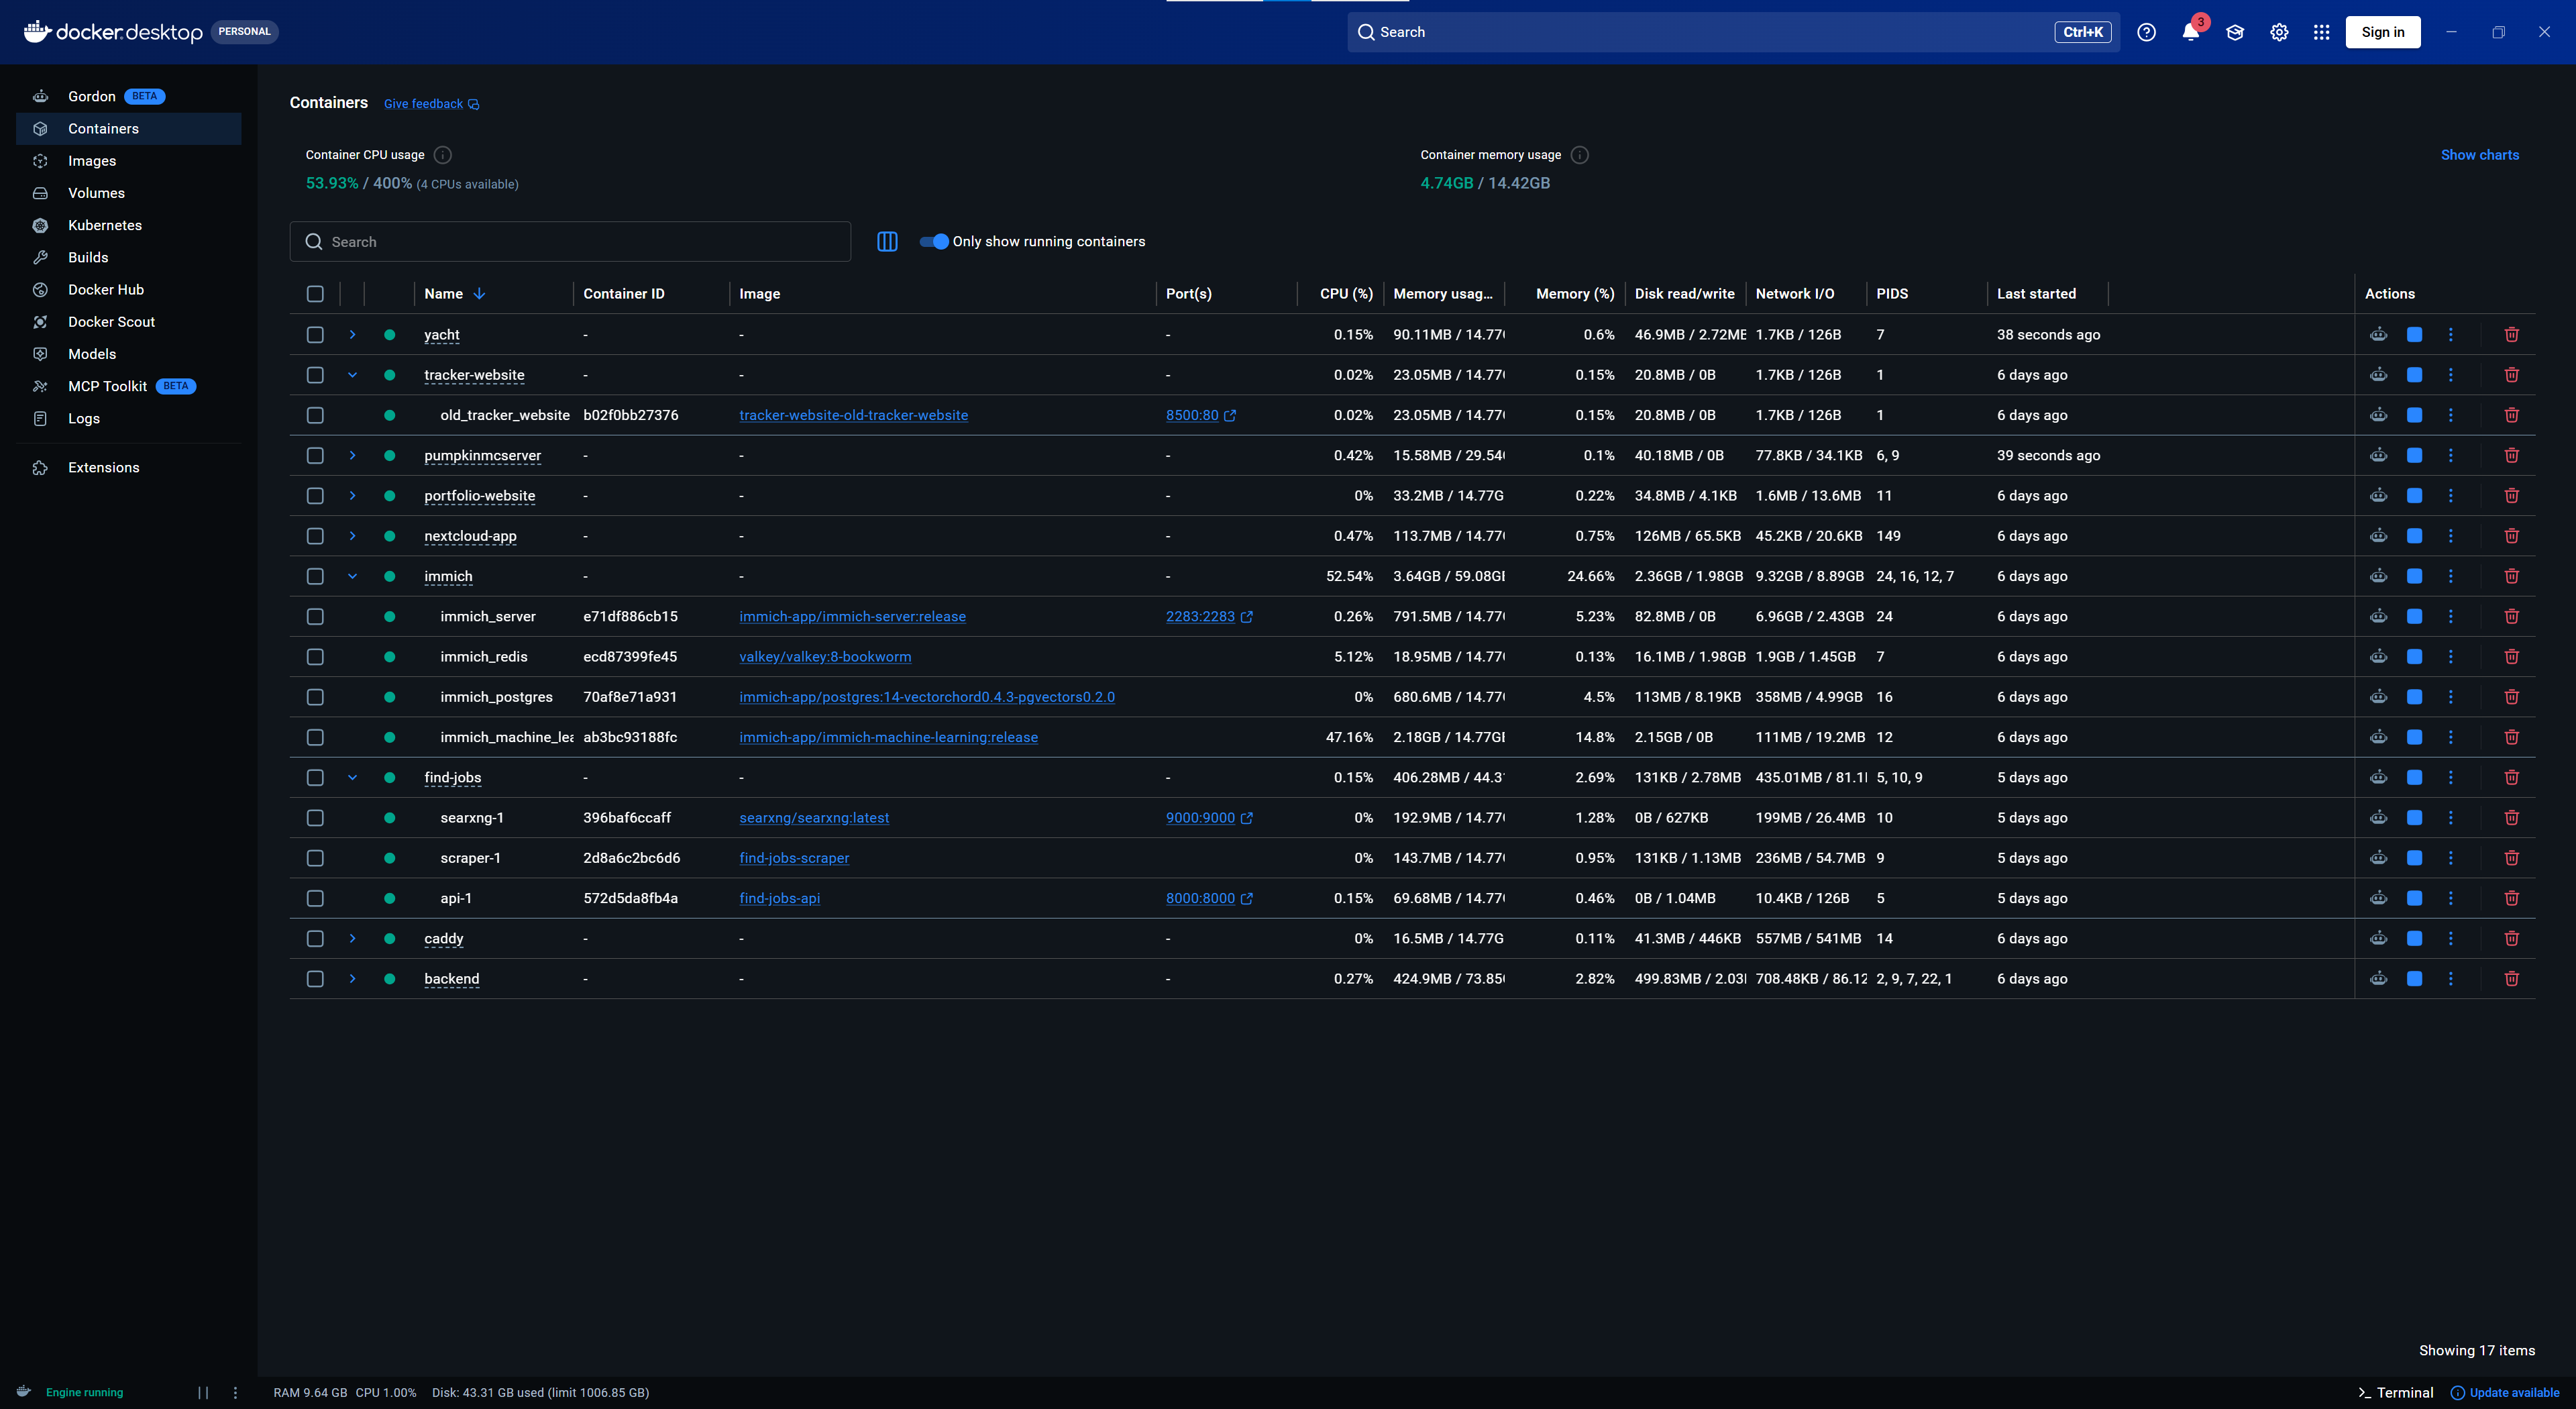
Built and deployed a Linux-based home server hosting a full suite of containerized full-stack web applications: an AI-assisted job tracker (FastAPI + locally hosted LLM ranking), a time journal (Python + SQL), a movie streaming platform, plus self-hosted cloud storage and cloud photo services.
6+ SERVICES · LOCAL LLM · SELF-HOSTED
UBC Physics Olympics
Team Lead · Engineer
Led a 20+ person team through provincial physics build challenges against 100+ competing schools. Prototyped a copper-plate cooler using stored momentum and a diode bridge. Designed a paper solar-powered boat with a custom EasyEDA PCB that harvests solar power and triggers a motor at a threshold voltage.
100+ SCHOOLS · 4+ PROTOTYPES · $100 BUDGET
What's being designed next.
Prosthetic Arm
A 6 DOF prosthetic robot arm engineered for dexterous manipulation. Cycloidal actuators at each joint for high torque density and backdrivability. Soft robotic hand joints for compliant, human-like grasping.
Ball-Balancing Robot
A mobile robot that actively balances and moves on top of a single ball. Uses real-time IMU sensor fusion, and inverse kinematics, to maintain balance and be controlled by a controller.
Technical Skills
Skills built from curiosity. Refined through execution.
About Me
I'm a Mechanical Engineering student with a passion for innovation, robotics, and design. I've designed fully autonomous piano-playing robots to award-winning robots from scratch.
I work across mechanical, electrical, and software systems, with a specialisation in mechanism design and rapid prototyping. I love turning ideas into reality, whether through CAD modelling, mechanical simulation, or hands-on fabrication. Beyond engineering, I mentor students in STEM and enjoy camping, skiing, and other outdoor activities.
The harmonograph behind this page is inspired by a four-pendulum harmonograph that I saw at a science exhibition. That style of systematic yet evolving art spoke to me and inspired me to create a web version of that style of art. Feel free to play with the harmonograph and feel the same satisfaction that I had when I was a child.
World Championship Design Award
VEX Robotics4x BC Provincial Championship Awards
VEX Robotics32x Regional Championship Awards
VEX Robotics7th Global TrueSkill Ranking
VEX RoboticsSenior Category Silver Medal
Vancouver Regional Science FairBronze Medal — Build Challenge
UBC Physics OlympicsLet's Build Something
Open to engineering internships, research collaborations, and interesting endeavors.